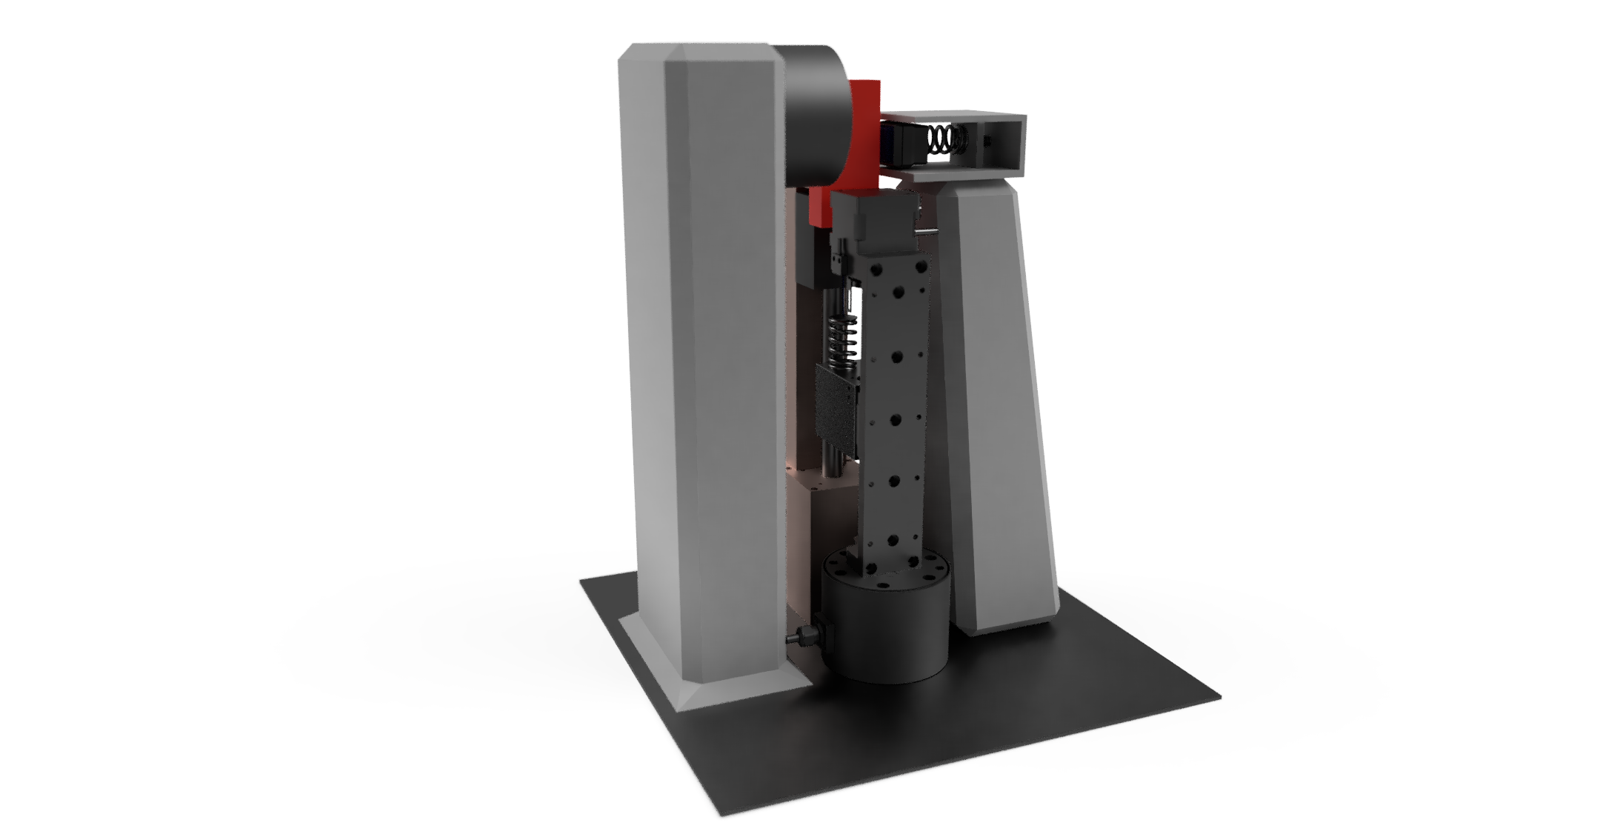
The slip-detection test bench next to a plot of GelSight-derived contact forces

Prediction of Slip Velocity for Control in Robotic Grippers via Transformer-Based Fusion of Visuotactile Data, Image Data, and Vibration Signals

Master’s thesis at TU Darmstadt: fusing GelSight images, tactile marker motion, and vibration signals to estimate slip velocity and predict it ahead of time for future gripper control.
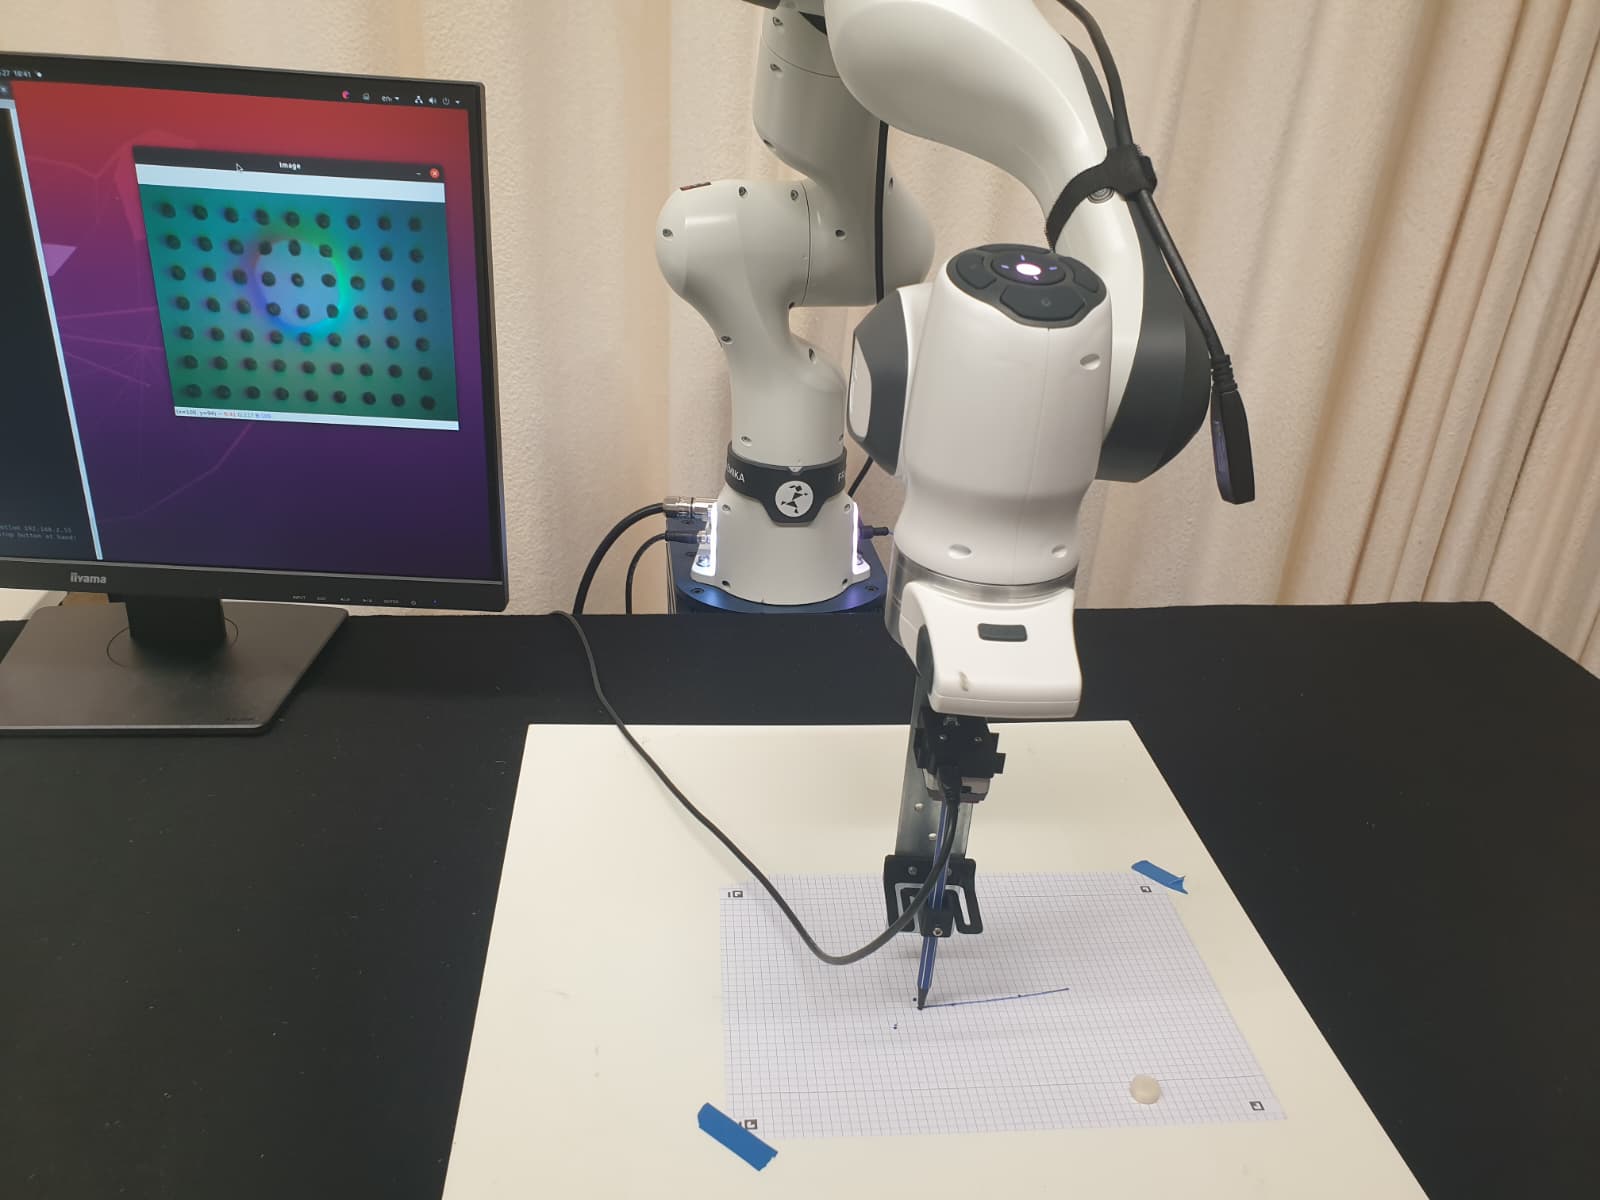
Franka robot arm drawing with a pen mounted through a visuo-tactile sensor

Tool Contact Force Estimation for Robot Drawing

A pen mounted on a Franka arm through a visuo-tactile sensor; computer-vision algorithms estimate the contact force at the pen tip.

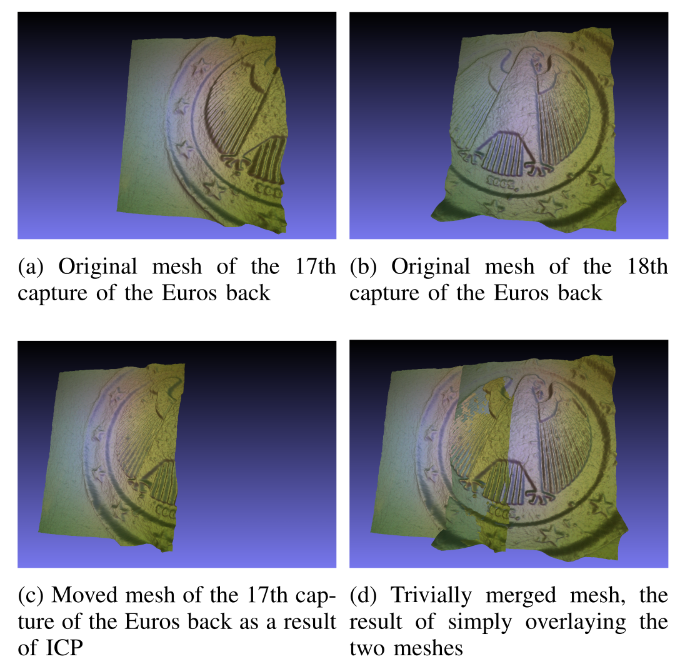
Raw GelSight capture of a Euro coin surface

3D Scanning and Measuring with Visuo-Tactile Sensors

3D point clouds and surface stitching from GelSight Mini tactile captures: reconstructing coin surfaces by touch alone.