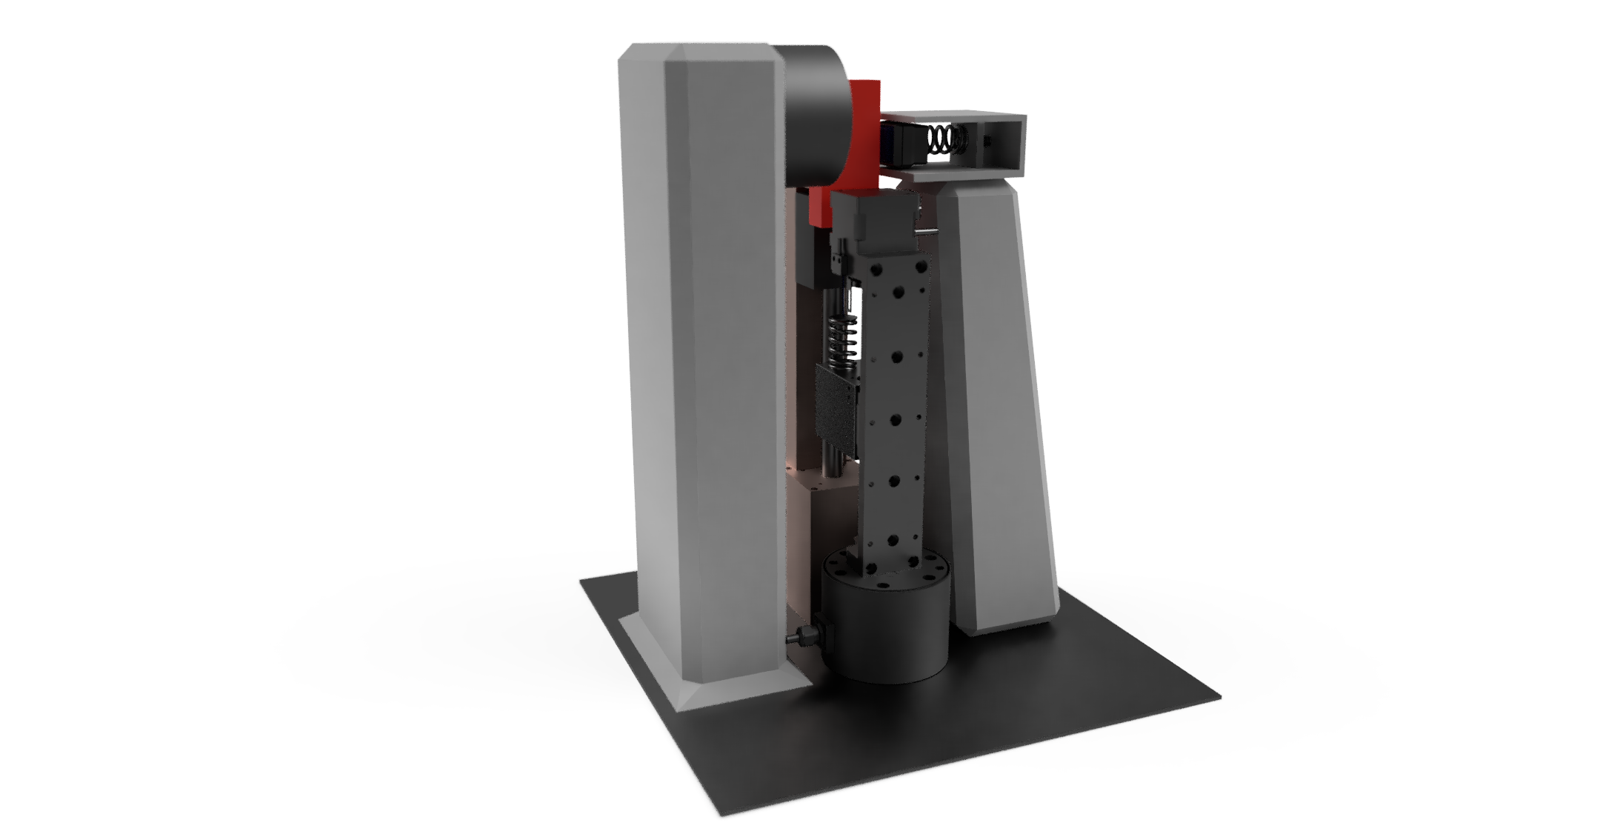
Prediction of Slip Velocity for Control in Robotic Grippers via Transformer-Based Fusion of Visuotactile Data, Image Data, and Vibration Signals
Master’s thesis at TU Darmstadt: fusing GelSight images, tactile marker motion, and vibration signals to estimate slip velocity and predict it ahead of time for future gripper control.