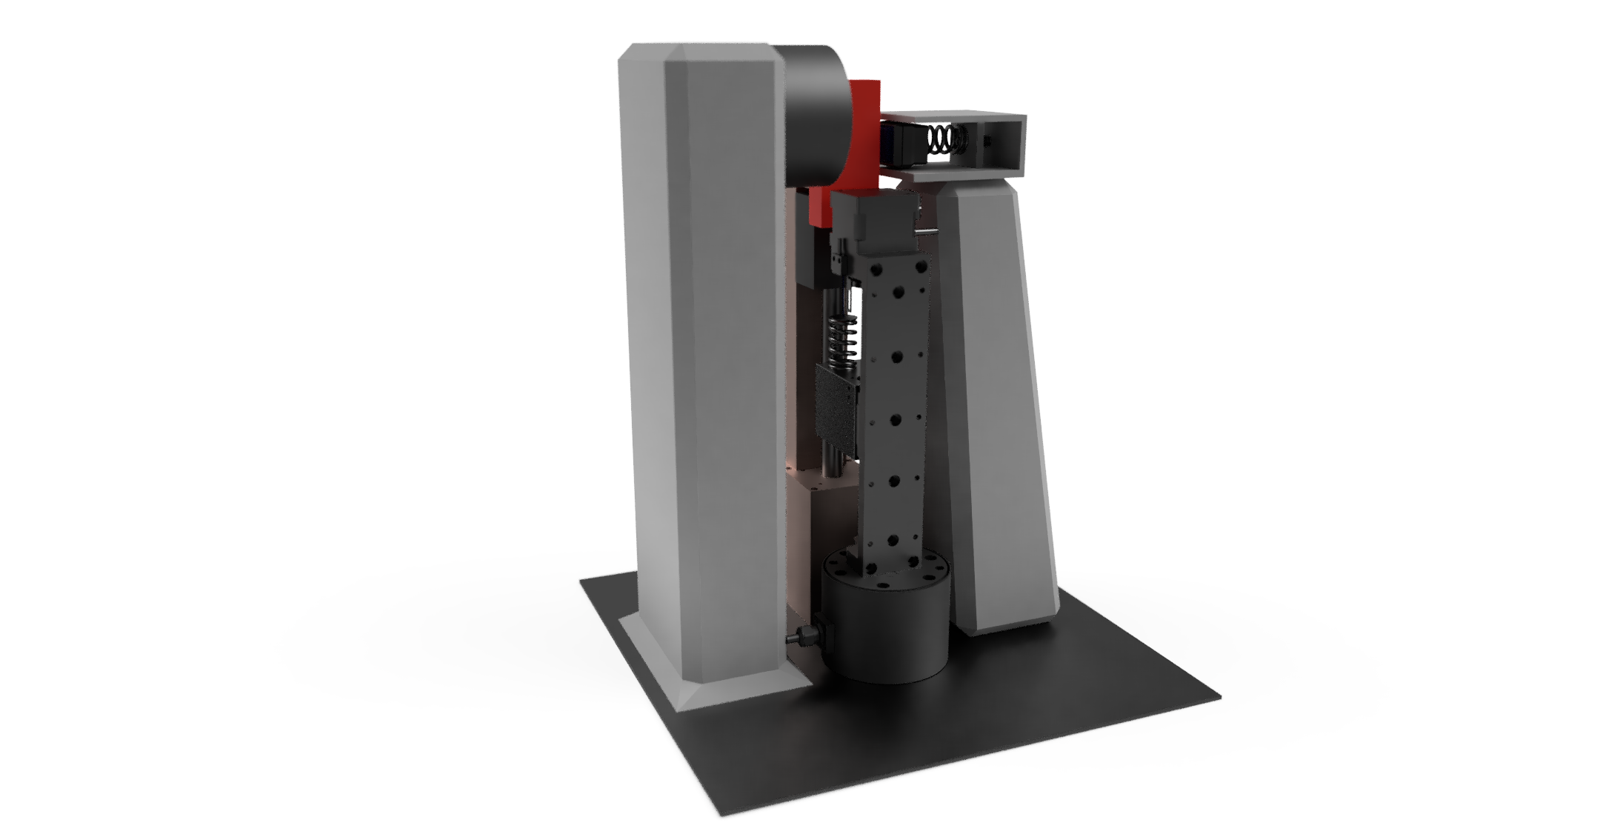
The slip-detection test bench next to a plot of GelSight-derived contact forces

Prediction of Slip Velocity for Control in Robotic Grippers via Transformer-Based Fusion of Visuotactile Data, Image Data, and Vibration Signals

Master’s thesis at TU Darmstadt: fusing GelSight images, tactile marker motion, and vibration signals to estimate slip velocity and predict it ahead of time for future gripper control.
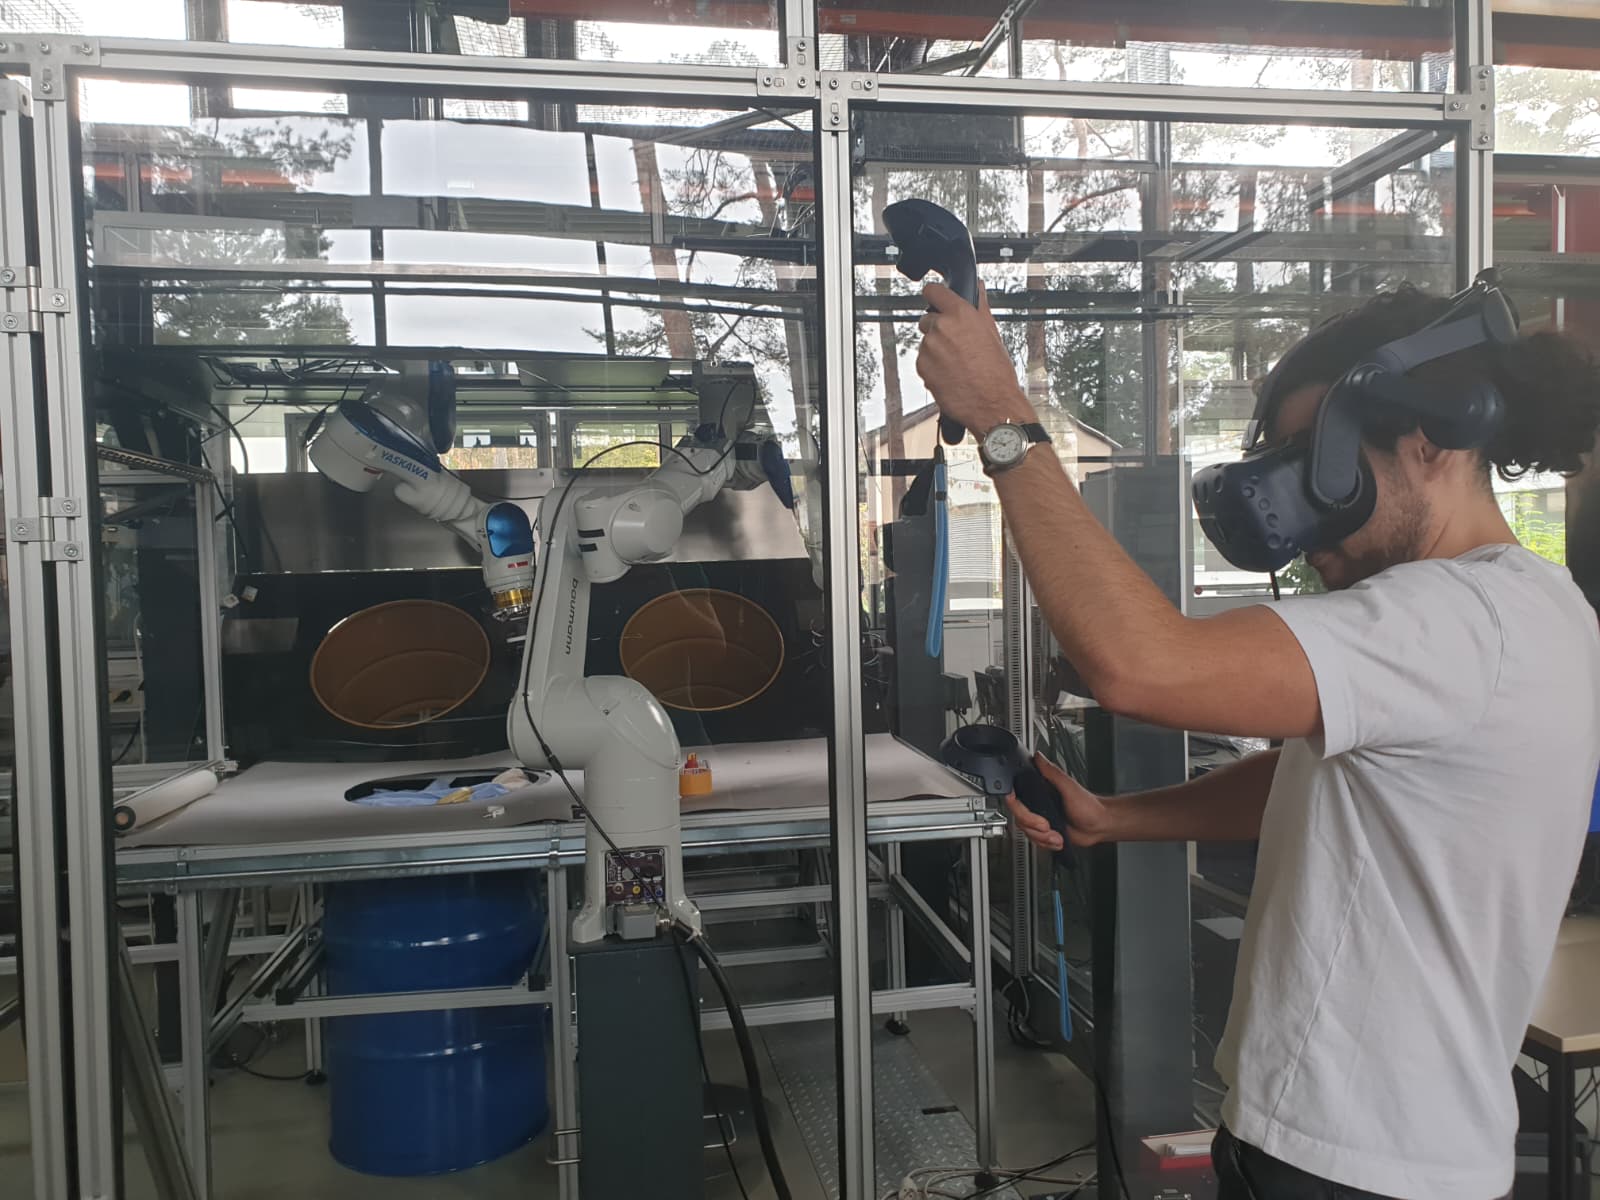
Overview of the bin-picking system: robot cell, part bins, and processing pipeline

Bachelor Thesis — Robotic Bin-Picking via Supervised and Imitation Learning

Neural network-based part selection for semi-autonomous bin-picking of radioactive waste, trained on VR teleoperation data. 73% grasp accuracy at +1.2 ms latency.

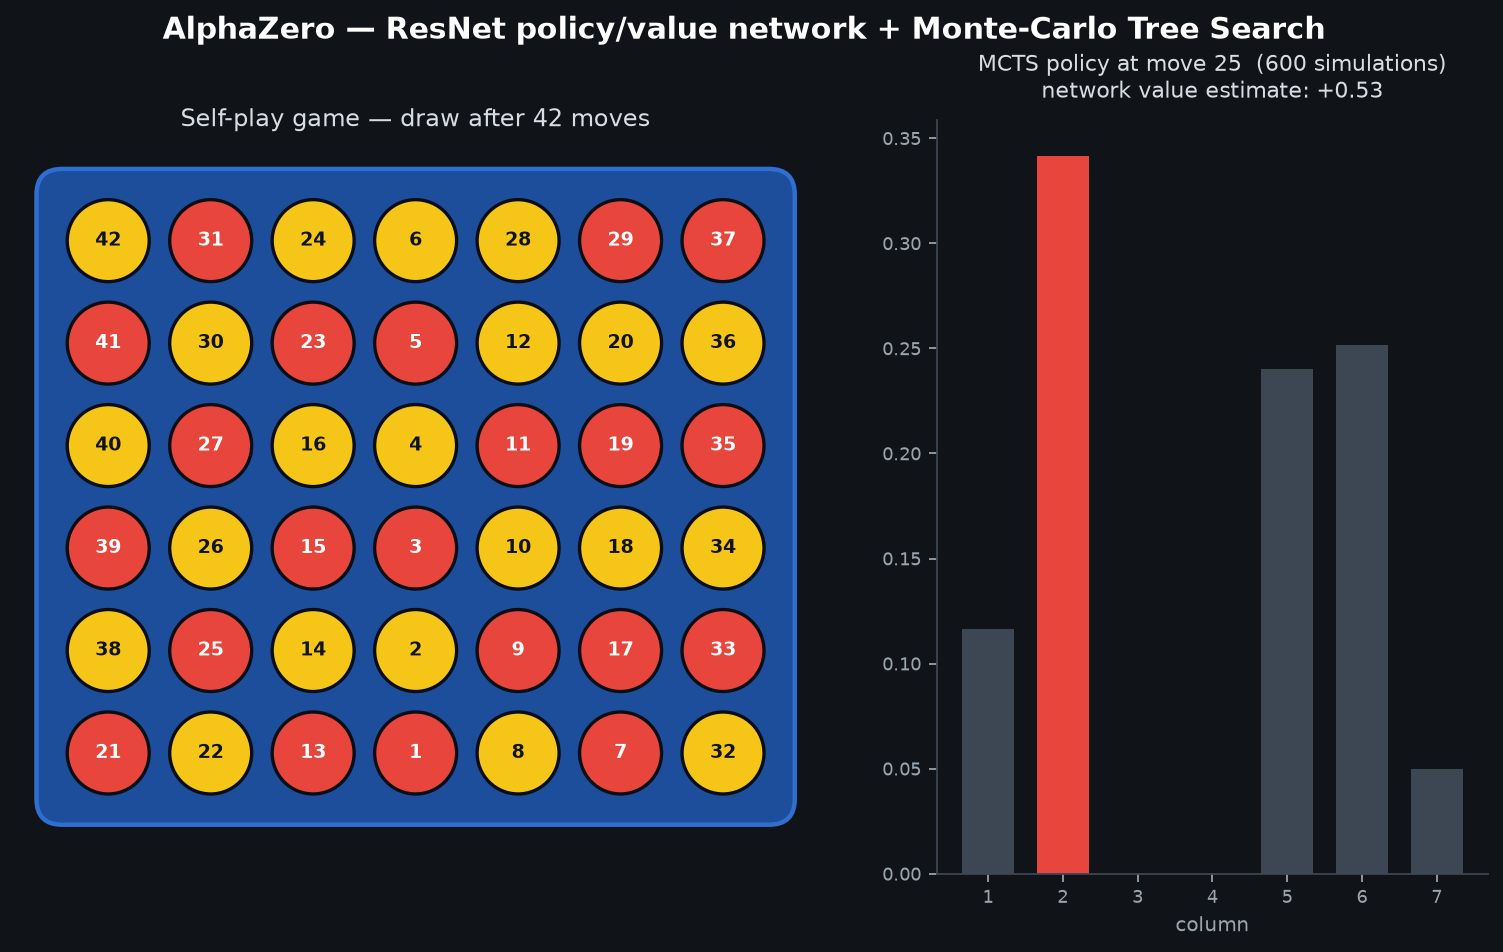
A completed AlphaZero self-play Connect Four game with move numbers, next to the MCTS policy distribution of a mid-game decision

Reinforcement Learning Agent in Games (AlphaZero)

AlphaZero-based framework that learns tic-tac-toe, Connect 4, and CartPole with a unified model architecture.